Cached values and derivatives for the centroidal-momentum task. More...
#include <centroidal-momentum.hpp>
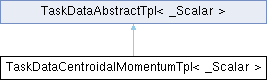
Public Types | |
| typedef TaskDataAbstractTpl< Scalar > | Base |
| typedef DataCollectorAbstractTpl< Scalar > | DataCollectorAbstract |
| typedef MathBaseTpl< Scalar > | MathBase |
| typedef MathBase::Matrix6xs | Matrix6xs |
| typedef MathBase::Vector6s | Vector6s |
| Public Types inherited from TaskDataAbstractTpl< _Scalar > | |
| typedef DataCollectorAbstractTpl< Scalar > | DataCollectorAbstract |
| typedef MathBaseTpl< Scalar > | MathBase |
| typedef MathBase::MatrixXs | MatrixXs |
| typedef TaskModelAbstractTpl< Scalar > | TaskModelAbstract |
| typedef MathBase::VectorXs | VectorXs |
Public Member Functions | |
| template<template< typename Scalar > class Model> | |
| TaskDataCentroidalMomentumTpl (Model< Scalar > *const model, DataCollectorAbstract *const data) | |
| Bind the task data to the shared Pinocchio data and, optionally, joint data. | |
| Public Member Functions inherited from TaskDataAbstractTpl< _Scalar > | |
| TaskDataAbstractTpl (TaskModelAbstract *const model, DataCollectorAbstract *const data) | |
| Allocate and initialize the common task data. | |
Public Attributes | |
| Matrix6xs | dh_dq |
| Partial derivative of h with respect to q. | |
| Matrix6xs | dhdot_da |
| Partial derivative of hdot with respect to ddq. | |
| Matrix6xs | dhdot_dq |
| Partial derivative of hdot with respect to q. | |
| Matrix6xs | dhdot_dv |
| Partial derivative of hdot with respect to v. | |
| Vector6s | hdot |
| Current centroidal-momentum rate. | |
| std::shared_ptr< JointDataAbstractTpl< Scalar > > | joint |
| Shared generalized-acceleration data. | |
| pinocchio::DataTpl< Scalar > * | pinocchio |
| Shared Pinocchio data. | |
| EIGEN_MAKE_ALIGNED_OPERATOR_NEW typedef _Scalar | Scalar |
| DataCollectorAbstract * | shared |
| Shared action-model data collector. | |
| Public Attributes inherited from TaskDataAbstractTpl< _Scalar > | |
| VectorXs | a |
Task acceleration  | |
| MatrixXs | Au |
Jacobian  | |
| MatrixXs | Ax |
Jacobian  | |
| bool | compute_acceleration |
| Request computation of task acceleration. | |
| EIGEN_MAKE_ALIGNED_OPERATOR_NEW typedef _Scalar | Scalar |
| DataCollectorAbstract * | shared |
| Shared action-model data collector. | |
| VectorXs | v |
Task rate  | |
| MatrixXs | Vu |
Jacobian  | |
| MatrixXs | Vx |
Jacobian  | |
| VectorXs | y |
Task quantity  | |
| MatrixXs | Yu |
Jacobian  | |
| MatrixXs | Yx |
Jacobian  | |
Detailed Description
struct crocoddyl::TaskDataCentroidalMomentumTpl< _Scalar >
Cached values and derivatives for the centroidal-momentum task.
Definition at line 143 of file centroidal-momentum.hpp.
Member Typedef Documentation
◆ MathBase
| typedef MathBaseTpl<Scalar> MathBase |
Definition at line 147 of file centroidal-momentum.hpp.
◆ Base
| typedef TaskDataAbstractTpl<Scalar> Base |
Definition at line 148 of file centroidal-momentum.hpp.
◆ DataCollectorAbstract
| typedef DataCollectorAbstractTpl<Scalar> DataCollectorAbstract |
Definition at line 149 of file centroidal-momentum.hpp.
◆ Vector6s
| typedef MathBase::Vector6s Vector6s |
Definition at line 150 of file centroidal-momentum.hpp.
◆ Matrix6xs
| typedef MathBase::Matrix6xs Matrix6xs |
Definition at line 151 of file centroidal-momentum.hpp.
Constructor & Destructor Documentation
◆ TaskDataCentroidalMomentumTpl()
| inline |
Bind the task data to the shared Pinocchio data and, optionally, joint data.
- Parameters
[in] model Centroidal-momentum task model [in] data Shared data derived from DataCollectorMultibodyTpl and, optionally, DataCollectorJointTpl
Definition at line 162 of file centroidal-momentum.hpp.
Member Data Documentation
◆ Scalar
| EIGEN_MAKE_ALIGNED_OPERATOR_NEW typedef _Scalar Scalar |
Definition at line 146 of file centroidal-momentum.hpp.
◆ pinocchio
| pinocchio::DataTpl<Scalar>* pinocchio |
Shared Pinocchio data.
Definition at line 192 of file centroidal-momentum.hpp.
◆ joint
| std::shared_ptr<JointDataAbstractTpl<Scalar> > joint |
Shared generalized-acceleration data.
Definition at line 194 of file centroidal-momentum.hpp.
◆ hdot
| Vector6s hdot |
Current centroidal-momentum rate.
Definition at line 195 of file centroidal-momentum.hpp.
◆ dh_dq
| Matrix6xs dh_dq |
Partial derivative of h with respect to q.
Definition at line 196 of file centroidal-momentum.hpp.
◆ dhdot_dq
| Matrix6xs dhdot_dq |
Partial derivative of hdot with respect to q.
Definition at line 197 of file centroidal-momentum.hpp.
◆ dhdot_dv
| Matrix6xs dhdot_dv |
Partial derivative of hdot with respect to v.
Definition at line 198 of file centroidal-momentum.hpp.
◆ dhdot_da
| Matrix6xs dhdot_da |
Partial derivative of hdot with respect to ddq.
Definition at line 199 of file centroidal-momentum.hpp.
◆ shared
| DataCollectorAbstract* shared |
Shared action-model data collector.
Definition at line 170 of file task-base.hpp.
The documentation for this struct was generated from the following files:
- /build/source/include/crocoddyl/multibody/fwd.hpp
- /build/source/include/crocoddyl/multibody/tasks/centroidal-momentum.hpp
