Frame rotation task model. More...
#include <frame-rotation.hpp>
Public Types | |
| typedef TaskModelAbstractTpl< Scalar > | Base |
| typedef TaskDataFrameRotationTpl< Scalar > | Data |
| typedef DataCollectorAbstractTpl< Scalar > | DataCollectorAbstract |
| typedef MathBaseTpl< Scalar > | MathBase |
| typedef MathBase::Matrix3s | Matrix3s |
| typedef MathBase::Matrix6xs | Matrix6xs |
| typedef pinocchio::MotionTpl< Scalar > | Motion |
| typedef StateMultibodyTpl< Scalar > | StateMultibody |
| typedef TaskDataAbstractTpl< Scalar > | TaskDataAbstract |
| typedef MathBase::Vector3s | Vector3s |
| typedef MathBase::VectorXs | VectorXs |
| Public Types inherited from TaskModelAbstractTpl< _Scalar > | |
| typedef DataCollectorAbstractTpl< Scalar > | DataCollectorAbstract |
| typedef MathBaseTpl< Scalar > | MathBase |
| typedef MathBase::MatrixXs | MatrixXs |
| typedef StateAbstractTpl< Scalar > | StateAbstract |
| typedef TaskDataAbstractTpl< Scalar > | TaskDataAbstract |
| typedef MathBase::VectorXs | VectorXs |
Public Member Functions | |
| TaskModelFrameRotationTpl (std::shared_ptr< StateMultibody > state, const pinocchio::FrameIndex id, const Matrix3s &Rref) | |
| Construct a frame rotation task with LOCAL reference frame. | |
| TaskModelFrameRotationTpl (std::shared_ptr< StateMultibody > state, const pinocchio::FrameIndex id, const Matrix3s &Rref, const pinocchio::ReferenceFrame type, const std::size_t nu) | |
| Construct a frame rotation task with an explicit reference frame. | |
| TaskModelFrameRotationTpl (std::shared_ptr< StateMultibody > state, const pinocchio::FrameIndex id, const Matrix3s &Rref, const std::size_t nu) | |
| Construct a frame rotation task with LOCAL reference frame. | |
| virtual void | calc (const std::shared_ptr< TaskDataAbstract > &data, const Eigen::Ref< const VectorXs > &x, const Eigen::Ref< const VectorXs > &u) override |
| Compute the task value and task rate. | |
| virtual void | calcDiff (const std::shared_ptr< TaskDataAbstract > &data, const Eigen::Ref< const VectorXs > &x, const Eigen::Ref< const VectorXs > &u) override |
| Compute the task Jacobians. | |
| template<typename NewScalar> | |
| TaskModelFrameRotationTpl< NewScalar > | cast () const |
| Cast the task model to a different scalar type. | |
| virtual std::shared_ptr< TaskDataAbstract > | createData (DataCollectorAbstract *const data) override |
| Allocate task data. | |
| pinocchio::FrameIndex | get_id () const |
| Return the frame index. | |
| const Matrix3s & | get_reference () const |
| Return the reference rotation. | |
| pinocchio::ReferenceFrame | get_type () const |
| Return the reference frame convention. | |
| virtual void | print (std::ostream &os) const override |
| Print relevant information. | |
| void | set_id (const pinocchio::FrameIndex id) |
| Update the frame index. | |
| void | set_reference (const Matrix3s &reference) |
| Update the reference rotation. | |
| void | set_type (const pinocchio::ReferenceFrame type) |
| Update the reference frame convention. | |
| Public Member Functions inherited from TaskModelAbstractTpl< _Scalar > | |
| TaskModelAbstractTpl (std::shared_ptr< StateAbstract > state, const std::size_t nr, const std::size_t nu, const bool q_dependent=true, const bool v_dependent=true, const bool u_dependent=true, const bool has_acceleration=true) | |
| Initialize the task model. | |
| bool | get_has_acceleration () const |
| Return whether the task defines an acceleration component. | |
| std::size_t | get_nr () const |
| std::size_t | get_nu () const |
| bool | get_q_dependent () const |
| const std::shared_ptr< StateAbstract > & | get_state () const |
| bool | get_u_dependent () const |
| bool | get_v_dependent () const |
Public Attributes | |
| EIGEN_MAKE_ALIGNED_OPERATOR_NEW typedef _Scalar | Scalar |
| Public Attributes inherited from TaskModelAbstractTpl< _Scalar > | |
| EIGEN_MAKE_ALIGNED_OPERATOR_NEW typedef _Scalar | Scalar |
Protected Attributes | |
| std::size_t | nr_ |
| std::size_t | nu_ |
| bool | q_dependent_ |
| std::shared_ptr< StateAbstract > | state_ |
| bool | u_dependent_ |
| bool | v_dependent_ |
| Protected Attributes inherited from TaskModelAbstractTpl< _Scalar > | |
| bool | has_acceleration_ |
| std::size_t | nr_ |
| std::size_t | nu_ |
| bool | q_dependent_ |
| std::shared_ptr< StateAbstract > | state_ |
| bool | u_dependent_ |
| bool | v_dependent_ |
Detailed Description
class crocoddyl::TaskModelFrameRotationTpl< _Scalar >
Frame rotation task model.
The task quantity 
- LOCAL:
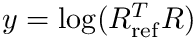
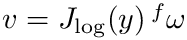
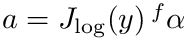
- WORLD and LOCAL_WORLD_ALIGNED:
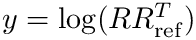
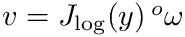
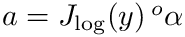


WORLD and LOCAL_WORLD_ALIGNED are equivalent here because only the angular component is used.
Definition at line 37 of file frame-rotation.hpp.
Member Typedef Documentation
◆ MathBase
| typedef MathBaseTpl<Scalar> MathBase |
Definition at line 43 of file frame-rotation.hpp.
◆ Base
| typedef TaskModelAbstractTpl<Scalar> Base |
Definition at line 44 of file frame-rotation.hpp.
◆ TaskDataAbstract
| typedef TaskDataAbstractTpl<Scalar> TaskDataAbstract |
Definition at line 45 of file frame-rotation.hpp.
◆ Data
| typedef TaskDataFrameRotationTpl<Scalar> Data |
Definition at line 46 of file frame-rotation.hpp.
◆ DataCollectorAbstract
| typedef DataCollectorAbstractTpl<Scalar> DataCollectorAbstract |
Definition at line 47 of file frame-rotation.hpp.
◆ StateMultibody
| typedef StateMultibodyTpl<Scalar> StateMultibody |
Definition at line 48 of file frame-rotation.hpp.
◆ Matrix3s
| typedef MathBase::Matrix3s Matrix3s |
Definition at line 49 of file frame-rotation.hpp.
◆ Matrix6xs
| typedef MathBase::Matrix6xs Matrix6xs |
Definition at line 50 of file frame-rotation.hpp.
◆ Vector3s
| typedef MathBase::Vector3s Vector3s |
Definition at line 51 of file frame-rotation.hpp.
◆ VectorXs
| typedef MathBase::VectorXs VectorXs |
Definition at line 52 of file frame-rotation.hpp.
◆ Motion
| typedef pinocchio::MotionTpl<Scalar> Motion |
Definition at line 53 of file frame-rotation.hpp.
Constructor & Destructor Documentation
◆ TaskModelFrameRotationTpl()
| TaskModelFrameRotationTpl | ( | std::shared_ptr< StateMultibody > | state, |
| const pinocchio::FrameIndex | id, | ||
| const Matrix3s & | Rref, | ||
| const std::size_t | nu ) |
Construct a frame rotation task with LOCAL reference frame.
The task dimension is fixed to 3 and the task does not depend on the control input.
Member Function Documentation
◆ calc()
| overridevirtual |
Compute the task value and task rate.
Implements TaskModelAbstractTpl< _Scalar >.
◆ calcDiff()
| overridevirtual |
Compute the task Jacobians.
Implements TaskModelAbstractTpl< _Scalar >.
◆ createData()
| overridevirtual |
Allocate task data.
Reimplemented from TaskModelAbstractTpl< _Scalar >.
◆ print()
| overridevirtual |
Print relevant information.
Reimplemented from TaskModelAbstractTpl< _Scalar >.
Member Data Documentation
◆ Scalar
| EIGEN_MAKE_ALIGNED_OPERATOR_NEW typedef _Scalar Scalar |
Definition at line 42 of file frame-rotation.hpp.
◆ nr_
| protected |
Definition at line 114 of file task-base.hpp.
◆ nu_
| protected |
Definition at line 115 of file task-base.hpp.
◆ q_dependent_
| protected |
Definition at line 116 of file task-base.hpp.
◆ state_
| protected |
Definition at line 113 of file task-base.hpp.
◆ u_dependent_
| protected |
Definition at line 118 of file task-base.hpp.
◆ v_dependent_
| protected |
Definition at line 117 of file task-base.hpp.
The documentation for this class was generated from the following files:
- /build/source/include/crocoddyl/multibody/fwd.hpp
- /build/source/include/crocoddyl/multibody/tasks/frame-rotation.hpp
