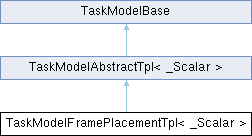
Frame placement task model. More...
#include <frame-placement.hpp>
Public Types | |
| typedef TaskModelAbstractTpl< Scalar > | Base |
| typedef TaskDataFramePlacementTpl< Scalar > | Data |
| typedef DataCollectorAbstractTpl< Scalar > | DataCollectorAbstract |
| typedef MathBaseTpl< Scalar > | MathBase |
| typedef MathBase::Matrix3s | Matrix3s |
| typedef MathBase::Matrix6s | Matrix6s |
| typedef pinocchio::MotionTpl< Scalar > | Motion |
| typedef pinocchio::SE3Tpl< Scalar > | SE3 |
| typedef StateMultibodyTpl< Scalar > | StateMultibody |
| typedef TaskDataAbstractTpl< Scalar > | TaskDataAbstract |
| typedef MathBase::VectorXs | VectorXs |
| Public Types inherited from TaskModelAbstractTpl< _Scalar > | |
| typedef DataCollectorAbstractTpl< Scalar > | DataCollectorAbstract |
| typedef MathBaseTpl< Scalar > | MathBase |
| typedef MathBase::MatrixXs | MatrixXs |
| typedef StateAbstractTpl< Scalar > | StateAbstract |
| typedef TaskDataAbstractTpl< Scalar > | TaskDataAbstract |
| typedef MathBase::VectorXs | VectorXs |
Public Member Functions | |
| TaskModelFramePlacementTpl (std::shared_ptr< StateMultibody > state, const pinocchio::FrameIndex id, const SE3 &pref) | |
| Construct a frame placement task using the default control dimension. | |
| TaskModelFramePlacementTpl (std::shared_ptr< StateMultibody > state, const pinocchio::FrameIndex id, const SE3 &pref, const pinocchio::ReferenceFrame type) | |
| Construct a frame placement task with an explicit reference frame. | |
| TaskModelFramePlacementTpl (std::shared_ptr< StateMultibody > state, const pinocchio::FrameIndex id, const SE3 &pref, const pinocchio::ReferenceFrame type, const std::size_t nu) | |
| Construct a frame placement task with an explicit reference frame. | |
| TaskModelFramePlacementTpl (std::shared_ptr< StateMultibody > state, const pinocchio::FrameIndex id, const SE3 &pref, const std::size_t nu) | |
| Construct a frame placement task. | |
| virtual void | calc (const std::shared_ptr< TaskDataAbstract > &data, const Eigen::Ref< const VectorXs > &x, const Eigen::Ref< const VectorXs > &u) override |
| Compute the task value and task rate. | |
| virtual void | calcDiff (const std::shared_ptr< TaskDataAbstract > &data, const Eigen::Ref< const VectorXs > &x, const Eigen::Ref< const VectorXs > &u) override |
| Compute the task Jacobians. | |
| template<typename NewScalar> | |
| TaskModelFramePlacementTpl< NewScalar > | cast () const |
| Cast the task model to a different scalar type. | |
| virtual std::shared_ptr< TaskDataAbstract > | createData (DataCollectorAbstract *const data) override |
| Allocate task data. | |
| pinocchio::FrameIndex | get_id () const |
| Return the frame index. | |
| const SE3 & | get_reference () const |
| Return the reference placement. | |
| pinocchio::ReferenceFrame | get_type () const |
| Return the reference frame convention. | |
| virtual void | print (std::ostream &os) const override |
| Print relevant information. | |
| void | set_id (const pinocchio::FrameIndex id) |
| Update the frame index. | |
| void | set_reference (const SE3 &reference) |
| Update the reference placement. | |
| void | set_type (const pinocchio::ReferenceFrame type) |
| Update the reference frame convention. | |
| Public Member Functions inherited from TaskModelAbstractTpl< _Scalar > | |
| TaskModelAbstractTpl (std::shared_ptr< StateAbstract > state, const std::size_t nr, const std::size_t nu, const bool q_dependent=true, const bool v_dependent=true, const bool u_dependent=true, const bool has_acceleration=true) | |
| Initialize the task model. | |
| bool | get_has_acceleration () const |
| Return whether the task defines an acceleration component. | |
| std::size_t | get_nr () const |
| std::size_t | get_nu () const |
| bool | get_q_dependent () const |
| const std::shared_ptr< StateAbstract > & | get_state () const |
| bool | get_u_dependent () const |
| bool | get_v_dependent () const |
Public Attributes | |
| EIGEN_MAKE_ALIGNED_OPERATOR_NEW typedef _Scalar | Scalar |
| Public Attributes inherited from TaskModelAbstractTpl< _Scalar > | |
| EIGEN_MAKE_ALIGNED_OPERATOR_NEW typedef _Scalar | Scalar |
Protected Attributes | |
| std::size_t | nr_ |
| std::size_t | nu_ |
| bool | q_dependent_ |
| std::shared_ptr< StateAbstract > | state_ |
| bool | u_dependent_ |
| bool | v_dependent_ |
| Protected Attributes inherited from TaskModelAbstractTpl< _Scalar > | |
| bool | has_acceleration_ |
| std::size_t | nr_ |
| std::size_t | nu_ |
| bool | q_dependent_ |
| std::shared_ptr< StateAbstract > | state_ |
| bool | u_dependent_ |
| bool | v_dependent_ |
Detailed Description
class crocoddyl::TaskModelFramePlacementTpl< _Scalar >
Frame placement task model.
The task quantity is a 6D pose error expressed in the selected reference frame. Let 


The three conventions are

The reference placement is always an absolute pose in the world. The task rate and acceleration use the same reference-frame convention as the error:

Here 

Definition at line 50 of file frame-placement.hpp.
Member Typedef Documentation
◆ MathBase
| typedef MathBaseTpl<Scalar> MathBase |
Definition at line 56 of file frame-placement.hpp.
◆ Base
| typedef TaskModelAbstractTpl<Scalar> Base |
Definition at line 57 of file frame-placement.hpp.
◆ TaskDataAbstract
| typedef TaskDataAbstractTpl<Scalar> TaskDataAbstract |
Definition at line 58 of file frame-placement.hpp.
◆ Data
| typedef TaskDataFramePlacementTpl<Scalar> Data |
Definition at line 59 of file frame-placement.hpp.
◆ DataCollectorAbstract
| typedef DataCollectorAbstractTpl<Scalar> DataCollectorAbstract |
Definition at line 60 of file frame-placement.hpp.
◆ StateMultibody
| typedef StateMultibodyTpl<Scalar> StateMultibody |
Definition at line 61 of file frame-placement.hpp.
◆ Matrix3s
| typedef MathBase::Matrix3s Matrix3s |
Definition at line 62 of file frame-placement.hpp.
◆ Matrix6s
| typedef MathBase::Matrix6s Matrix6s |
Definition at line 63 of file frame-placement.hpp.
◆ VectorXs
| typedef MathBase::VectorXs VectorXs |
Definition at line 64 of file frame-placement.hpp.
◆ Motion
| typedef pinocchio::MotionTpl<Scalar> Motion |
Definition at line 65 of file frame-placement.hpp.
◆ SE3
| typedef pinocchio::SE3Tpl<Scalar> SE3 |
Definition at line 66 of file frame-placement.hpp.
Member Function Documentation
◆ calc()
| overridevirtual |
Compute the task value and task rate.
Implements TaskModelAbstractTpl< _Scalar >.
◆ calcDiff()
| overridevirtual |
Compute the task Jacobians.
Implements TaskModelAbstractTpl< _Scalar >.
◆ createData()
| overridevirtual |
Allocate task data.
Reimplemented from TaskModelAbstractTpl< _Scalar >.
◆ print()
| overridevirtual |
Print relevant information.
Reimplemented from TaskModelAbstractTpl< _Scalar >.
Member Data Documentation
◆ Scalar
| EIGEN_MAKE_ALIGNED_OPERATOR_NEW typedef _Scalar Scalar |
Definition at line 55 of file frame-placement.hpp.
◆ nr_
| protected |
Definition at line 114 of file task-base.hpp.
◆ nu_
| protected |
Definition at line 115 of file task-base.hpp.
◆ q_dependent_
| protected |
Definition at line 116 of file task-base.hpp.
◆ state_
| protected |
Definition at line 113 of file task-base.hpp.
◆ u_dependent_
| protected |
Definition at line 118 of file task-base.hpp.
◆ v_dependent_
| protected |
Definition at line 117 of file task-base.hpp.
The documentation for this class was generated from the following files:
- /build/source/include/crocoddyl/multibody/fwd.hpp
- /build/source/include/crocoddyl/multibody/tasks/frame-placement.hpp
