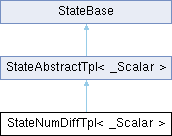
Public Types | |
| typedef StateAbstractTpl< _Scalar > | Base |
| typedef MathBaseTpl< Scalar > | MathBase |
| typedef MathBase::MatrixXs | MatrixXs |
| typedef MathBase::VectorXs | VectorXs |
| Public Types inherited from StateAbstractTpl< _Scalar > | |
| typedef MathBaseTpl< Scalar > | MathBase |
| typedef MathBase::MatrixXs | MatrixXs |
| typedef MathBase::VectorXs | VectorXs |
Public Member Functions | |
| StateNumDiffTpl (std::shared_ptr< Base > state) | |
| template<typename NewScalar> | |
| StateNumDiffTpl< NewScalar > | cast () const |
| virtual void | diff (const Eigen::Ref< const VectorXs > &x0, const Eigen::Ref< const VectorXs > &x1, Eigen::Ref< VectorXs > dxout) const override |
| Compute the state manifold differentiation. | |
| const Scalar | get_disturbance () const |
| Return the disturbance constant used in the numerical differentiation routine. | |
| virtual void | integrate (const Eigen::Ref< const VectorXs > &x, const Eigen::Ref< const VectorXs > &dx, Eigen::Ref< VectorXs > xout) const override |
| Compute the state manifold integration. | |
| virtual void | Jdiff (const Eigen::Ref< const VectorXs > &x0, const Eigen::Ref< const VectorXs > &x1, Eigen::Ref< MatrixXs > Jfirst, Eigen::Ref< MatrixXs > Jsecond, Jcomponent firstsecond=both) const override |
| This computes the Jacobian of the diff method by finite differentiation: | |
| virtual void | Jintegrate (const Eigen::Ref< const VectorXs > &x, const Eigen::Ref< const VectorXs > &dx, Eigen::Ref< MatrixXs > Jfirst, Eigen::Ref< MatrixXs > Jsecond, const Jcomponent firstsecond=both, const AssignmentOp op=setto) const override |
| This computes the Jacobian of the integrate method by finite differentiation: | |
| virtual void | JintegrateTransport (const Eigen::Ref< const VectorXs > &x, const Eigen::Ref< const VectorXs > &dx, Eigen::Ref< MatrixXs > Jin, const Jcomponent firstsecond=both) const override |
| Parallel transport from integrate(x, dx) to x. | |
| virtual void | print (std::ostream &os) const override |
| Print relevant information of the state numdiff. | |
| virtual VectorXs | rand () const override |
| Generate a random state. | |
| void | set_disturbance (const Scalar disturbance) |
| Modify the disturbance constant used by the numerical differentiation routine. | |
| virtual VectorXs | zero () const override |
| Generate a zero state. | |
| Public Member Functions inherited from StateAbstractTpl< _Scalar > | |
| StateAbstractTpl (const std::size_t nx, const std::size_t ndx) | |
| Initialize the state dimensions. | |
| VectorXs | diff_dx (const Eigen::Ref< const VectorXs > &x0, const Eigen::Ref< const VectorXs > &x1) |
| Compute the state manifold differentiation. | |
| bool | get_has_limits () const |
| Indicate if the state has defined limits. | |
| const VectorXs & | get_lb () const |
| Return the state lower bound. | |
| std::size_t | get_ndx () const |
| Return the dimension of the tangent space of the state manifold. | |
| std::size_t | get_nq () const |
| Return the dimension of the configuration tuple. | |
| std::size_t | get_nv () const |
| Return the dimension of tangent space of the configuration manifold. | |
| std::size_t | get_nx () const |
| Return the dimension of the state tuple. | |
| const VectorXs & | get_ub () const |
| Return the state upper bound. | |
| VectorXs | integrate_x (const Eigen::Ref< const VectorXs > &x, const Eigen::Ref< const VectorXs > &dx) |
| Compute the state manifold integration. | |
| std::vector< MatrixXs > | Jdiff_Js (const Eigen::Ref< const VectorXs > &x0, const Eigen::Ref< const VectorXs > &x1, const Jcomponent firstsecond=both) |
| std::vector< MatrixXs > | Jintegrate_Js (const Eigen::Ref< const VectorXs > &x, const Eigen::Ref< const VectorXs > &dx, const Jcomponent firstsecond=both) |
| Compute the Jacobian of the state manifold integration. | |
| virtual void | safe_diff (const Eigen::Ref< const VectorXs > &x0, const Eigen::Ref< const VectorXs > &x1, Eigen::Ref< VectorXs > dxout) const |
| Sanitized diff operator that neutralises invalid components and propagates NaNs where the result cannot be trusted". | |
| virtual void | safe_integrate (const Eigen::Ref< const VectorXs > &x, const Eigen::Ref< const VectorXs > &dx, Eigen::Ref< VectorXs > xout) const |
| Sanitized integrate operator that clamps invalid inputs and marks affected configuration or velocity entries with NaNs. | |
| void | set_lb (const VectorXs &lb) |
| Modify the state lower bound. | |
| void | set_ub (const VectorXs &ub) |
| Modify the state upper bound. | |
Public Attributes | |
| EIGEN_MAKE_ALIGNED_OPERATOR_NEW typedef _Scalar | Scalar |
| Public Attributes inherited from StateAbstractTpl< _Scalar > | |
| EIGEN_MAKE_ALIGNED_OPERATOR_NEW typedef _Scalar | Scalar |
Protected Attributes | |
| bool | has_limits_ |
| Indicates whether any of the state limits is finite. | |
| VectorXs | lb_ |
| Lower state limits. | |
| std::size_t | ndx_ |
| State rate dimension. | |
| std::size_t | nq_ |
| Configuration dimension. | |
| std::size_t | nv_ |
| Velocity dimension. | |
| std::size_t | nx_ |
| State dimension. | |
| VectorXs | ub_ |
| Upper state limits. | |
| Protected Attributes inherited from StateAbstractTpl< _Scalar > | |
| bool | has_limits_ |
| Indicates whether any of the state limits is finite. | |
| VectorXs | lb_ |
| Lower state limits. | |
| std::size_t | ndx_ |
| State rate dimension. | |
| std::size_t | nq_ |
| Configuration dimension. | |
| std::size_t | nv_ |
| Velocity dimension. | |
| std::size_t | nx_ |
| State dimension. | |
| VectorXs | ub_ |
| Upper state limits. | |
Additional Inherited Members | |
| Protected Member Functions inherited from StateAbstractTpl< _Scalar > | |
| void | update_has_limits () |
Detailed Description
class crocoddyl::StateNumDiffTpl< _Scalar >
Member Typedef Documentation
◆ MathBase
| typedef MathBaseTpl<Scalar> MathBase |
◆ Base
| typedef StateAbstractTpl<_Scalar> Base |
◆ VectorXs
| typedef MathBase::VectorXs VectorXs |
◆ MatrixXs
| typedef MathBase::MatrixXs MatrixXs |
Member Function Documentation
◆ zero()
| overridevirtual |
Generate a zero state.
Implements StateAbstractTpl< _Scalar >.
◆ rand()
| overridevirtual |
Generate a random state.
Implements StateAbstractTpl< _Scalar >.
◆ diff()
| overridevirtual |
Compute the state manifold differentiation.
The state differentiation is defined as:

where 


- Parameters
[in] x0 Previous state point (size nx) [in] x1 Current state point (size nx) [out] dxout Difference between the current and previous state points (size ndx)
Implements StateAbstractTpl< _Scalar >.
◆ integrate()
| overridevirtual |
Compute the state manifold integration.
The state integration is defined as:

where 


- Parameters
[in] x State point (size nx) [in] dx Velocity vector (size ndx) [out] xout Next state point (size nx)
Implements StateAbstractTpl< _Scalar >.
◆ Jdiff()
| overridevirtual |
This computes the Jacobian of the diff method by finite differentiation:

and

- Parameters
Jfirst Jsecond firstsecond
Implements StateAbstractTpl< _Scalar >.
◆ Jintegrate()
| overridevirtual |
This computes the Jacobian of the integrate method by finite differentiation:

and

- Parameters
Jfirst Jsecond firstsecond
Implements StateAbstractTpl< _Scalar >.
◆ JintegrateTransport()
| overridevirtual |
Parallel transport from integrate(x, dx) to x.
This function performs the parallel transportation of an input matrix whose columns are expressed in the tangent space at 
- Parameters
[in] x State point (size nx). [in] dx Velocity vector (size ndx) [out] Jin Input matrix (number of rows = nv). [in] firstsecond Argument (either x or dx) with respect to which the differentiation of Jintegrate is performed.
Implements StateAbstractTpl< _Scalar >.
◆ print()
| overridevirtual |
Print relevant information of the state numdiff.
- Parameters
[out] os Output stream object
Reimplemented from StateAbstractTpl< _Scalar >.
Member Data Documentation
◆ Scalar
| EIGEN_MAKE_ALIGNED_OPERATOR_NEW typedef _Scalar Scalar |
◆ has_limits_
| protected |
Indicates whether any of the state limits is finite.
Definition at line 364 of file state-base.hpp.
◆ lb_
| protected |
Lower state limits.
Definition at line 362 of file state-base.hpp.
◆ ndx_
| protected |
State rate dimension.
Definition at line 359 of file state-base.hpp.
◆ nq_
| protected |
Configuration dimension.
Definition at line 360 of file state-base.hpp.
◆ nv_
| protected |
Velocity dimension.
Definition at line 361 of file state-base.hpp.
◆ nx_
| protected |
State dimension.
Definition at line 358 of file state-base.hpp.
◆ ub_
| protected |
Upper state limits.
Definition at line 363 of file state-base.hpp.
The documentation for this class was generated from the following files:
