Loading...
Searching...
No Matches
SolverDDP Class Reference
Differential Dynamic Programming (DDP) solver. More...
#include <ddp-deprecated.hpp>
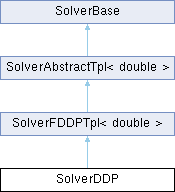
Inheritance diagram for SolverDDP:
Public Member Functions | |
| virtual void | calcDiff () |
| EIGEN_MAKE_ALIGNED_OPERATOR_NEW | DEPRECATED ("Do not use SolverDDP. Instead, you should use SolverFDDP(problem, " "DynamicsSolverType::SingleShoot)", explicit SolverDDP(std::shared_ptr< ShootingProblemTpl< double > > problem) :SolverFDDPTpl< double >(problem){};) virtual ~SolverDDP()=default |
| Initialize the DDP solver. | |
| Public Member Functions inherited from SolverFDDPTpl< double > | |
| SolverFDDPTpl (std::shared_ptr< ShootingProblem > problem, const DynamicsSolverType dyn_solver=FeasShoot, const EqualitySolverType term_solver=LuNull) | |
| Initialize the FDDP solver. | |
| virtual void | backwardPass () |
| Run the backward pass (Riccati sweep). | |
| void | batchPass () |
| Run the batch pass to account for its constraints. | |
| SolverFDDPTpl< NewScalar > | cast () const |
| Cast the FDDP solver to a different scalar type. | |
| virtual bool | checkAcceptance () override |
| Check if we should accept or not the step. | |
| virtual void | computeActionValueFunction (const std::size_t t, const std::shared_ptr< ActionModelAbstract > &model, const std::shared_ptr< ActionDataAbstract > &data) |
| Compute the linear-quadratic approximation of the control action-value function. | |
| virtual void | computeBatchActionValueFunction (const std::size_t t, const std::shared_ptr< ActionDataAbstract > &data) |
| Compute the linear-quadratic approximation of the control action-value function associated to the batch's constraints. | |
| virtual void | computeBatchPolicy (const std::size_t t) |
| Compute the feedforward and feedback terms (control policy) associated to the batch's constraints. | |
| virtual void | computeBatchValueFunction (const std::size_t t) |
| Compute the linear-quadratic approximation of the value function associated to the batch's constraints. | |
| virtual void | computeCandidate (const Scalar step_length=Scalar(1.)) override |
| Compute new candidate solution using step length. | |
| virtual void | computeDirection (const bool recalc=true) override |
Compute the search direction   | |
| Scalar | computeDynamicFeasibility () |
Compute the dynamic feasibility   | |
| Scalar | computeEqualityFeasibility () |
| Compute the feasibility of the equality constraints for the current guess. | |
| virtual void | computeExpectedMeritFunctionImprovement () override |
| Compute the expected merit function improvement for the current step. | |
| Scalar | computeFeasibility (const std::vector< VectorXs > &fs) |
| Compute the feasibility from a given residual vector. | |
| Scalar | computeInequalityFeasibility () |
| Compute the feasibility of the inequality constraints for the current guess. | |
| virtual void | computeMeritFunctionImprovement () override |
| Compute the merit function improvement for the current step. | |
| virtual void | computePolicy (const std::size_t t) |
| Compute the feedforward and feedback terms (control policy) computed via a Cholesky decomposition. | |
| virtual void | computeValueFunction (const std::size_t t, const std::shared_ptr< ActionModelAbstract > &model) |
| Compute the linear-quadratic approximation of the value function. | |
| void | decreaseRegularization () override |
| Decrease the state and control regularization values by a regfactor_ factor. | |
| bool | decreaseRegularizationCriteria () override |
| Criteria used to decrease regularization. | |
| virtual Vector3s | expectedImprovement () override |
Return the expected improvement  | |
| virtual void | feasShootForwardPass (const Scalar steplength) |
| Run the feasibility-driven nonlinear rollout. | |
| void | forwardPass (const Scalar steplength=Scalar(1.)) |
| Perform a forward pass with a predefined step length. | |
| const VectorXs & | get_beta_plus () const |
Return the next terminal-constraint multiplier  | |
| const MatrixXs & | get_dHc () const |
Return the Jacobian of the terminal constraint gains  | |
| const std::vector< MatrixXs > & | get_dUc () const |
Return the linear update in  | |
| const std::vector< MatrixXs > & | get_dXc () const |
Return the linear update in  | |
| DynamicsSolverType | get_dynamics_solver () const |
| Return the type of solver used for handling the dynamics constraints. | |
| const VectorXs & | get_hc () const |
Return the bias term of the terminal constraint gains  | |
| const std::vector< MatrixXsRowMajor > & | get_K () const |
Return the feedback gains  | |
| const std::vector< VectorXs > & | get_k () const |
Return the feedforward gains  | |
| const std::vector< MatrixXs > & | get_Kc () const |
Return the feedforward gains  | |
| const std::vector< VectorXs > & | get_Qu () const |
Return the Jacobian of the Hamiltonian function  | |
| const std::vector< MatrixXs > & | get_Quc () const |
Return the Hessian of the Hamiltonian function  | |
| const std::vector< MatrixXs > & | get_Quu () const |
Return the Hessian of the Hamiltonian function  | |
| const std::vector< VectorXs > & | get_Qx () const |
Return the Jacobian of the Hamiltonian function  | |
| const std::vector< MatrixXs > & | get_Qxc () const |
Return the Hessian of the Hamiltonian function  | |
| const std::vector< MatrixXs > & | get_Qxu () const |
Return the Hessian of the Hamiltonian function  | |
| const std::vector< MatrixXs > & | get_Qxx () const |
Return the Hessian of the Hamiltonian function  | |
| Scalar | get_reg_decfactor () const |
| Return the regularization factor used to decrease the damping value. | |
| Scalar | get_reg_incfactor () const |
| Return the regularization factor used to increase the damping value. | |
| Scalar | get_rho () const |
| Return the rho parameter used in the merit function. | |
| EqualitySolverType | get_terminal_solver () const |
| Return the type of solver used for handling the terminal constraints. | |
| Scalar | get_th_acceptminstep () const |
| Return the threshold used for accepting minimum steps. | |
| Scalar | get_th_acceptnegstep () const |
| Return the threshold used for accepting step along ascent direction. | |
| Scalar | get_th_grad () const |
| Return the tolerance of the expected gradient used for testing the step. | |
| Scalar | get_th_minfeas () const |
| Return the threshold for switching to feasibility. | |
| Scalar | get_th_minimprove () const |
| Return the minimum improvement threshold used to increase regularization. | |
| Scalar | get_th_stepdec () const |
| Return the step-length threshold used to decrease regularization. | |
| Scalar | get_th_stepinc () const |
| Return the step-length threshold used to increase regularization. | |
| const std::vector< std::size_t > & | get_Ts () const |
| Return the hybrid shooting intervals. | |
| Scalar | get_upsilon () const |
| Return the estimated penalty parameter that balances relative contribution of the cost function and equality constraints. | |
| Scalar | get_upsilon_decfactor () const |
| Return the upsilon decresing factor used to estimate to balance optimality and feasibility. | |
| const std::vector< VectorXs > & | get_Vx () const |
Return the Hessian of the Value function  | |
| const std::vector< MatrixXs > & | get_Vxc () const |
Return the Hessian of the Value function  | |
| const std::vector< MatrixXs > & | get_Vxx () const |
Return the Hessian of the Value function  | |
| bool | get_zero_upsilon () const |
| Return the zero-upsilon label. | |
| virtual void | hybridShootForwardPass (const Scalar steplength) |
| Run the multiple-shooting rollout with intervals of feasibility-driven search. | |
| void | increaseRegularization () override |
| Increase the state and control regularization values by a regfactor_ factor. | |
| bool | increaseRegularizationCriteria () override |
| Criteria used to increase regularization. | |
| void | linearRollout () |
| Perform a linear rollout give the current control policy. | |
| virtual void | multiShootForwardPass (const Scalar steplength) |
| Run the multiple-shooting rollout. | |
| virtual void | resizeData () |
| Resizing the solver data. | |
| void | set_dynamics_solver (const DynamicsSolverType type, const std::size_t Tshoot=0) |
| Set the dynamic solver used for handling the dynamics constraints. | |
| void | set_reg_decfactor (const Scalar reg_factor) |
| Modify the regularization factor used to decrease the damping value. | |
| void | set_reg_incfactor (const Scalar reg_factor) |
| Modify the regularization factor used to increase the damping value. | |
| void | set_rho (const Scalar rho) |
| Modify the rho parameter used in the merit function. | |
| void | set_terminal_solver (const EqualitySolverType type) |
| Set the type of solver used for handling the terminal constraints. | |
| void | set_th_acceptminstep (const Scalar th_acceptminstep) |
| Modify the threshold used for accepting minimum steps. | |
| void | set_th_acceptnegstep (const Scalar th_acceptnegstep) |
| Modify the threshold used for accepting step along ascent direction. | |
| void | set_th_grad (const Scalar th_grad) |
| Modify the tolerance of the expected gradient used for testing the step. | |
| void | set_th_minfeas (const Scalar th_minfeas) |
| Modify the threshold for switching to feasibility. | |
| void | set_th_minimprove (const Scalar th_step) |
| Modify the minimum improvement threshold used to increase regularization. | |
| void | set_th_noimprovement (const Scalar th_noimprovement) |
| Modify the threshold used to accept steps that cannot be be improved due to numerical errors the th noimprovement object. | |
| void | set_th_stepdec (const Scalar th_step) |
| Modify the step-length threshold used to decrease regularization. | |
| void | set_th_stepinc (const Scalar th_step) |
| Modify the step-length threshold used to increase regularization. | |
| void | set_upsilon_decfactor (const Scalar th_step) |
| Modify the upsilon decresing factor used to estimate to balance optimality and feasibility. | |
| void | set_zero_upsilon (const bool zero_upsilon) |
| Modify the zero-upsilon label. | |
| virtual void | singleShootForwardPass (const Scalar steplength) |
| Run the classical nonlinear rollout. | |
| virtual Scalar | stoppingCriteria () override |
| Return a positive value that quantifies the algorithm termination. | |
| void | updateCandidate () override |
| Update the candidate solution: cost, feasibilities, and merit value. | |
| void | updateDir () |
| Update search direction associated with the batch's constraints. | |
| virtual void | updateDualsAndSlacks (const Scalar stepLength=Scalar(1.)) |
| Update the dual and slack variables with a predefined step length. | |
| virtual void | updateMeritFunction () override |
| Update the merit function value for the current guess. | |
| Public Member Functions inherited from SolverAbstractTpl< double > | |
| SolverAbstractTpl (std::shared_ptr< ShootingProblem > problem) | |
| Initialize the solver. | |
| virtual void | calcDir () |
| Refresh the linearization of the optimal control problem around the current candidate. | |
| Scalar | computeControlFeasibility (const std::vector< VectorXs > &us) |
| Compute the control box-constraint feasibility from a given control trajectory. | |
| Scalar | computeDynamicFeasibility () |
| Compute the dynamic feasibility | |
| Scalar | computeEqualityFeasibility () |
| Compute the feasibility of the equality constraints for the current guess. | |
| Scalar | computeFeasibility (const std::vector< VectorXs > &fs) |
| Compute the feasibility from a given residual vector. | |
| Scalar | computeInequalityFeasibility () |
| Compute the feasibility of the inequality constraints for the current guess. | |
| Scalar | computeStateFeasibility (const std::vector< VectorXs > &xs) |
| Compute the state box-constraint feasibility from a given state trajectory. | |
| DEPRECATED ("Do not use this threshold. It is not needed by our solvers", Scalar get_th_gaptol() const { return th_gaptol_;}) FeasibilityNorm get_feasnorm() const | |
| Return the threshold for accepting a gap as non-zero. | |
| DEPRECATED ("Do not use this threshold. It is not needed by our solvers", void set_th_gaptol(const Scalar th_gaptol);) void set_feasnorm(const FeasibilityNorm feas_norm) | |
| Modify the threshold for accepting a gap as non-zero. | |
| DEPRECATED ("Use get_preg for primal-variable regularization", Scalar get_xreg() const { return preg_;}) DEPRECATED("Use get_preg for primal-variable regularization" | |
| DEPRECATED ("Use set_preg for primal-variable regularization", void set_xreg(const Scalar xreg) { if(xreg< Scalar(0.)) { throw_pretty("Invalid argument: "<< "xreg value has to be positive.");} xreg_=xreg;preg_=xreg;}) DEPRECATED("Use set_preg for primal-variable regularization" | |
| const std::vector< Scalar > & | get_alphas () const |
| Return the set of step lengths using by the line-search procedure. | |
| Scalar | get_cost () const |
| Return the cost for the current guess. | |
| Scalar | get_dfeas () const |
| Return the reduction in the feasibility. | |
| Scalar | get_dPhi () const |
Return the reduction in the merit function  | |
| Scalar | get_dPhiexp () const |
Return the expected reduction in the merit function  | |
| Scalar | get_dreg () const |
| Return the dual-variable regularization. | |
| const std::vector< VectorXs > & | get_dus () const |
Return the feedforward gains  | |
| const Vector3s & | get_DV () const |
| Return the constant, linear, and quadratic terms of the expected improvement. | |
| Scalar | get_dV () const |
Return the reduction in the cost function  | |
| Scalar | get_dVexp () const |
Return the expected reduction in the cost function  | |
| const std::vector< VectorXs > & | get_dxs () const |
Return the linear update in  | |
| Scalar | get_feas () const |
| Return the total feasibility for the current guess. | |
| Scalar | get_ffeas () const |
| Return the dynamic feasibility for the current guess. | |
| Scalar | get_ffeas_try () const |
| Return the dynamic feasibility for the current step length. | |
| const std::vector< VectorXs > & | get_fs () const |
Return the dynamic infeasibility  | |
| const std::vector< VectorXs > & | get_fs_try () const |
| Return the trail dynamic infeasibility | |
| Scalar | get_gfeas () const |
| Return the inequality feasibility for the current guess. | |
| Scalar | get_gfeas_try () const |
| Return the inequality feasibility for the current step length. | |
| Scalar | get_hfeas () const |
| Return the equality feasibility for the current guess. | |
| Scalar | get_hfeas_try () const |
| Return the equality feasibility for the current step length. | |
| bool | get_is_feasible () const |
Return the feasibility status of the  | |
| std::size_t | get_iter () const |
| Return the number of iterations performed by the solver. | |
| Scalar | get_merit () const |
| Return the merit for the current guess. | |
| Scalar | get_preg () const |
| Return the primal-variable regularization. | |
| const std::shared_ptr< ShootingProblem > & | get_problem () const |
| Return the shooting problem. | |
| Scalar | get_reg_max () const |
| Return the maximum regularization value. | |
| Scalar | get_reg_min () const |
| Return the minimum regularization value. | |
| Scalar | get_steplength () const |
Return the step length  | |
| Scalar | get_stop () const |
| Return the stopping-criteria value computed by stoppingCriteria(). | |
| Scalar | get_th_acceptstep () const |
| Return the threshold used for accepting a step. | |
| Scalar | get_th_stop () const |
| Return the tolerance for stopping the algorithm. | |
| Scalar | get_ureg () const |
| const std::vector< VectorXs > & | get_us () const |
Return the control trajectory  | |
| const std::vector< VectorXs > & | get_us_try () const |
| Return the trial control trajectory | |
| const std::vector< VectorXs > & | get_xs () const |
Return the state trajectory  | |
| const std::vector< VectorXs > & | get_xs_try () const |
| Return the trial state trajectory | |
| const std::vector< std::shared_ptr< CallbackAbstract > > & | getCallbacks () const |
| Return the list of callback functions using for diagnostic. | |
| void | set_alphas (const std::vector< Scalar > &alphas) |
| Modify the set of step lengths using by the line-search procedure. | |
| void | set_dreg (const Scalar dreg) |
| Modify the dual-variable regularization value. | |
| void | set_preg (const Scalar preg) |
| Modify the primal-variable regularization value. | |
| void | set_reg_max (const Scalar regmax) |
| Modify the maximum regularization value. | |
| void | set_reg_min (const Scalar regmin) |
| Modify the minimum regularization value. | |
| void | set_th_acceptstep (const Scalar th_acceptstep) |
| Modify the threshold used for accepting step. | |
| void | set_th_stop (const Scalar th_stop) |
| Modify the tolerance for stopping the algorithm. | |
| void | set_ureg (const Scalar ureg) |
| void | set_us (const std::vector< VectorXs > &us) |
| Modify the control trajectory | |
| void | set_xs (const std::vector< VectorXs > &xs) |
| Modify the state trajectory | |
| void | setCallbacks (const std::vector< std::shared_ptr< CallbackAbstract > > &callbacks) |
| Set a list of callback functions using for the solver diagnostic. | |
| virtual void | setCandidate (const std::vector< VectorXs > &xs_warm=DefaultVector< Scalar >::value, const std::vector< VectorXs > &us_warm=DefaultVector< Scalar >::value, const bool is_feasible=false) |
| Set the solver candidate trajectories | |
| virtual bool | solve (const std::vector< VectorXs > &init_xs=DefaultVector< Scalar >::value, const std::vector< VectorXs > &init_us=DefaultVector< Scalar >::value, const std::size_t maxiter=100, const bool is_feasible=false, const Scalar reg_init=std::numeric_limits< Scalar >::quiet_NaN()) |
Compute the optimal trajectory    | |
| virtual Scalar | tryStep (const Scalar steplength=Scalar(1.)) |
Try a predefined step length   | |
Additional Inherited Members | |
| Public Types inherited from SolverFDDPTpl< double > | |
| typedef ShootingProblem::ActionDataAbstract | ActionDataAbstract |
| typedef ShootingProblem::ActionModelAbstract | ActionModelAbstract |
| typedef CallbackAbstractTpl< Scalar > | CallbackAbstract |
| typedef MathBaseTpl< Scalar > | MathBase |
| typedef MathBase::MatrixXs | MatrixXs |
| typedef MathBase::MatrixXsRowMajor | MatrixXsRowMajor |
| typedef ShootingProblemTpl< Scalar > | ShootingProblem |
| typedef SolverAbstractTpl< Scalar > | SolverAbstract |
| typedef MathBase::Vector3s | Vector3s |
| typedef MathBase::VectorXs | VectorXs |
| Public Types inherited from SolverAbstractTpl< double > | |
| typedef ShootingProblem::ActionDataAbstract | ActionDataAbstract |
| typedef ShootingProblem::ActionModelAbstract | ActionModelAbstract |
| typedef CallbackAbstractTpl< Scalar > | CallbackAbstract |
| typedef MathBaseTpl< Scalar > | MathBase |
| typedef ShootingProblemTpl< Scalar > | ShootingProblem |
| typedef MathBase::Vector3s | Vector3s |
| typedef MathBase::VectorXs | VectorXs |
| Public Attributes inherited from SolverFDDPTpl< double > | |
| EIGEN_MAKE_ALIGNED_OPERATOR_NEW typedef double | Scalar |
| Public Attributes inherited from SolverAbstractTpl< double > | |
| EIGEN_MAKE_ALIGNED_OPERATOR_NEW typedef double | Scalar |
| Protected Member Functions inherited from SolverFDDPTpl< double > | |
| void | allocateData () |
| Allocate all the internal data needed for the solver. | |
| void | computeNullTerminalMultiplier () |
| compute the multiplier associated to the terminal constraint | |
| virtual void | resizeRunningData () override |
| Resize data associated with the running models of the shooting problem. | |
| virtual void | resizeTerminalData () override |
| Resize data associated with the terminal model of the shooting problem. | |
| Protected Member Functions inherited from SolverAbstractTpl< double > | |
| void | allocateData () |
| Allocate all the basic data needed in solvers. | |
| DEPRECATED ("Do not use this threshold. It is not needed by our solvers", Scalar th_gaptol_;) enum FeasibilityNorm feasnorm_ | |
| DEPRECATED ("Use preg_ for primal-variable regularization", Scalar xreg_;) DEPRECATED("Use dreg_ for primal-variable regularization" | |
| Protected Attributes inherited from SolverFDDPTpl< double > | |
| std::vector< VectorXs > | dx_ |
| State error during the roll-out/forward-pass (size T). | |
| DynamicsSolverType | dyn_solver_ |
| Type of dynamics solver. | |
| VectorXs | fTVxx_p_ |
| std::vector< MatrixXsRowMajor > | FuTVxx_p_ |
| std::vector< MatrixXsRowMajor > | FxTVxx_p_ |
| std::vector< MatrixXsRowMajor > | K_ |
Feedback gains  | |
| std::vector< VectorXs > | k_ |
Feed-forward terms  | |
| std::vector< VectorXs > | Luu_du_ |
| std::vector< VectorXs > | Lxu_du_ |
| std::vector< VectorXs > | Lxx_dx_ |
| std::vector< VectorXs > | Qu_ |
Gradient of the Hamiltonian  | |
| std::vector< MatrixXs > | Quu_ |
Hessian of the Hamiltonian  | |
| std::vector< Eigen::LLT< MatrixXs > > | Quu_llt_ |
| Cholesky LLT solver. | |
| std::vector< VectorXs > | Qx_ |
Gradient of the Hamiltonian  | |
| std::vector< MatrixXs > | Qxu_ |
Hessian of the Hamiltonian  | |
| std::vector< MatrixXs > | Qxx_ |
Hessian of the Hamiltonian  | |
| Scalar | reg_decfactor_ |
| Scalar | reg_incfactor_ |
| Scalar | rho_ |
| EqualitySolverType | term_solver_ |
| Type of terminal solver. | |
| Scalar | th_acceptminstep_ |
| Scalar | th_acceptnegstep_ |
| Scalar | th_grad_ |
| Scalar | th_minfeas_ |
| Threshold for switching to feasibility. | |
| Scalar | th_minimprove_ |
| Scalar | th_noimprovement_ |
| Scalar | th_stepdec_ |
| Step-length threshold used to decrease regularization. | |
| Scalar | th_stepinc_ |
| Step-length threshold used to increase regularization. | |
| std::vector< std::size_t > | Ts_ |
| Index that describes the hybrid shoots. | |
| Scalar | upsilon_ |
| Scalar | upsilon_decfactor_ |
| std::vector< VectorXs > | Vx_ |
Gradient of the Value function  | |
| std::vector< MatrixXs > | Vxx_ |
Hessian of the Value function  | |
| std::vector< VectorXs > | Vxx_f_ |
| MatrixXs | Vxx_tmp_ |
| Temporary variable for ensuring symmetry of Vxx. | |
| bool | zero_upsilon_ |
| Protected Attributes inherited from SolverAbstractTpl< double > | |
| bool | acceptstep_ |
| std::vector< Scalar > | alphas_ |
| Set of step lengths using by the line-search procedure. | |
| std::vector< std::shared_ptr< CallbackAbstract > > | callbacks_ |
| Callback functions. | |
| Scalar | cost_ |
| Cost for the current guess. | |
| Scalar | cost_try_ |
| Total cost computed by line-search procedure. | |
| Scalar | dfeas_ |
| Reduction in the feasibility. | |
| Scalar | dImpr_ |
| Scalar | dPhi_ |
| Reduction in the merit function computed by tryStep(). | |
| Scalar | dPhiexp_ |
| Scalar | dreg_ |
| Current dual-variable regularization value. | |
| std::vector< VectorXs > | dus_ |
| Linear control direction (size T). | |
| Vector3s | DV_ |
| LQ approximation of the expected improvement. | |
| Scalar | dV_ |
| Reduction in the cost function computed by tryStep(). | |
| Scalar | dVexp_ |
| Scalar | dVexp_full_ |
| std::vector< VectorXs > | dxs_ |
| Linear state direction (size T + 1). | |
| Scalar | feas_ |
| Total feasibility for the current guess. | |
| Scalar | ffeas_ |
| Feasibility of the dynamic constraints for the current guess. | |
| Scalar | ffeas_try_ |
| std::vector< VectorXs > | fs_ |
| Dynamics gaps in each node. | |
| std::vector< VectorXs > | fs_try_ |
| std::vector< VectorXs > | g_adj_ |
| Adjusted inequality bound. | |
| Scalar | gfeas_ |
| Scalar | gfeas_try_ |
| Scalar | hfeas_ |
| Scalar | hfeas_try_ |
| bool | is_feasible_ |
| Label that indicates is the iteration is feasible. | |
| std::size_t | iter_ |
| Number of iteration performed by the solver. | |
| Scalar | merit_ |
| Merit for the current guess. | |
| std::size_t | ng_T_ |
| Dimension of termianl inequality constraints. | |
| std::size_t | nh_T_ |
| Dimension of terminal equality constraints. | |
| Scalar | preg_ |
| Current primal-variable regularization value. | |
| std::shared_ptr< ShootingProblem > | problem_ |
| optimal control problem | |
| bool | recalcdir_ |
| Scalar | reg_max_ |
| Maximum allowed regularization value. | |
| Scalar | reg_min_ |
| < Current control regularization values | |
| Scalar | steplength_ |
| Current applied step length. | |
| Scalar | stop_ |
| Value computed by stoppingCriteria(). | |
| Scalar | th_acceptstep_ |
| Threshold used for accepting step. | |
| Scalar | th_stop_ |
| Tolerance for stopping the algorithm. | |
| Scalar | tmp_feas_ |
| Temporal variables used for computed the feasibility. | |
| std::vector< VectorXs > | u_adj_ |
| Adjusted control bound. | |
| Scalar | ureg_ |
| std::vector< VectorXs > | us_ |
| Control trajectory. | |
| std::vector< VectorXs > | us_try_ |
| Control trajectory computed by line-search procedure. | |
| bool | was_feasible_ |
| std::vector< VectorXs > | x_adj_ |
| Adjusted state bound. | |
| std::vector< VectorXs > | xs_ |
| State trajectory. | |
| std::vector< VectorXs > | xs_try_ |
| State trajectory computed by line-search procedure. | |
Detailed Description
Differential Dynamic Programming (DDP) solver.
The DDP solver computes an optimal trajectory and control commands by iterates running backwardPass() and forwardPass(). The backward-pass updates locally the quadratic approximation of the problem and computes descent direction. If the warm-start is feasible, then it computes the gaps 

Then, the forward-pass rollouts this new policy by integrating the system dynamics along a tuple of optimized control commands 

- See also
- SolverAbstract(), backwardPass() and forwardPass()
Definition at line 51 of file ddp-deprecated.hpp.
Member Function Documentation
◆ DEPRECATED()
| default |
Initialize the DDP solver.
- Parameters
[in] problem shooting problem
◆ calcDiff()
| inlinevirtual |
Definition at line 67 of file ddp-deprecated.hpp.
The documentation for this class was generated from the following file:
- /build/source/include/crocoddyl/core/solvers/ddp-deprecated.hpp
