Direction-preserving, smoothly bounded guidance model. More...
#include <smooth-saturation.hpp>
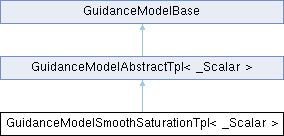
Public Types | |
| typedef GuidanceModelAbstractTpl< Scalar > | Base |
| typedef GuidanceDataSmoothSaturationTpl< Scalar > | Data |
| typedef Base::GuidanceDataAbstract | GuidanceDataAbstract |
| typedef MathBaseTpl< Scalar > | MathBase |
| typedef MathBase::MatrixXs | MatrixXs |
| typedef MathBase::VectorXs | VectorXs |
| Public Types inherited from GuidanceModelAbstractTpl< _Scalar > | |
| typedef GuidanceDataAbstractTpl< Scalar > | GuidanceDataAbstract |
| typedef MathBaseTpl< Scalar > | MathBase |
| typedef MathBase::MatrixXs | MatrixXs |
| typedef MathBase::VectorXs | VectorXs |
Public Member Functions | |
| GuidanceModelSmoothSaturationTpl (const std::size_t nr, const Scalar &gain, const Scalar &max_rate, const Scalar epsilon=Scalar(1e-6)) | |
| Initialize the smoothly saturated guidance model. | |
| virtual void | calc (const std::shared_ptr< GuidanceDataAbstract > &data, const Eigen::Ref< const VectorXs > &error) const override |
| Compute the smooth-saturation guidance output. | |
| virtual void | calcDiff (const std::shared_ptr< GuidanceDataAbstract > &data, const Eigen::Ref< const VectorXs > &error) const override |
| Compute the Jacobian of the smooth-saturation law. | |
| template<typename NewScalar> | |
| GuidanceModelSmoothSaturationTpl< NewScalar > | cast () const |
| Cast the guidance model to a different scalar type. | |
| virtual std::shared_ptr< GuidanceDataAbstract > | createData () const override |
| Allocate the cached guidance data. | |
| const Scalar & | get_epsilon () const |
| Return the smoothing parameter. | |
| const Scalar & | get_gain () const |
| Return the local linear gain. | |
| const Scalar & | get_max_rate () const |
| Return the maximum desired-rate norm. | |
| virtual void | print (std::ostream &os) const override |
| Print the model parameters. | |
| void | set_epsilon (const Scalar &epsilon) |
| Update the smoothing parameter. | |
| void | set_gain (const Scalar &gain) |
| Update the local linear gain. | |
| void | set_max_rate (const Scalar &max_rate) |
| Update the maximum desired-rate norm. | |
| Public Member Functions inherited from GuidanceModelAbstractTpl< _Scalar > | |
| GuidanceModelAbstractTpl (const std::size_t nr) | |
| Initialize the guidance-model dimension. | |
| std::size_t | get_nr () const |
| Return the error and desired-rate dimension. | |
Public Attributes | |
| EIGEN_MAKE_ALIGNED_OPERATOR_NEW typedef _Scalar | Scalar |
| Public Attributes inherited from GuidanceModelAbstractTpl< _Scalar > | |
| EIGEN_MAKE_ALIGNED_OPERATOR_NEW typedef _Scalar | Scalar |
Additional Inherited Members | |
| Protected Member Functions inherited from GuidanceModelAbstractTpl< _Scalar > | |
| void | checkErrorDimension (const Eigen::Ref< const VectorXs > &error) const |
| void | checkJacobianDimension (const Eigen::Ref< const MatrixXs > &Ge) const |
| void | checkRateDimension (const Eigen::Ref< const VectorXs > &g) const |
| Protected Attributes inherited from GuidanceModelAbstractTpl< _Scalar > | |
| std::size_t | nr_ |
Detailed Description
class crocoddyl::GuidanceModelSmoothSaturationTpl< _Scalar >
Direction-preserving, smoothly bounded guidance model.
This law is intended for Euclidean tasks with homogeneous units and implements the smooth saturation law

It is smooth at the origin, approaches 

Definition at line 34 of file smooth-saturation.hpp.
Member Typedef Documentation
◆ Base
| typedef GuidanceModelAbstractTpl<Scalar> Base |
Definition at line 41 of file smooth-saturation.hpp.
◆ GuidanceDataAbstract
| typedef Base::GuidanceDataAbstract GuidanceDataAbstract |
Definition at line 42 of file smooth-saturation.hpp.
◆ Data
| typedef GuidanceDataSmoothSaturationTpl<Scalar> Data |
Definition at line 43 of file smooth-saturation.hpp.
◆ MathBase
| typedef MathBaseTpl<Scalar> MathBase |
Definition at line 44 of file smooth-saturation.hpp.
◆ VectorXs
| typedef MathBase::VectorXs VectorXs |
Definition at line 45 of file smooth-saturation.hpp.
◆ MatrixXs
| typedef MathBase::MatrixXs MatrixXs |
Definition at line 46 of file smooth-saturation.hpp.
Constructor & Destructor Documentation
◆ GuidanceModelSmoothSaturationTpl()
| GuidanceModelSmoothSaturationTpl | ( | const std::size_t | nr, |
| const Scalar & | gain, | ||
| const Scalar & | max_rate, | ||
| const Scalar | epsilon = Scalar(1e-6) ) |
Initialize the smoothly saturated guidance model.
- Parameters
[in] nr Task dimension. [in] gain Local linear gain 
[in] max_rate Maximum desired-rate norm 
[in] epsilon Smoothing parameter 


Member Function Documentation
◆ calc()
| overridevirtual |
Compute the smooth-saturation guidance output.
- Parameters
[in,out] data Preallocated guidance data. [in] error Task error 

Implements GuidanceModelAbstractTpl< _Scalar >.
◆ calcDiff()
| overridevirtual |
Compute the Jacobian of the smooth-saturation law.
- Parameters
[in,out] data Preallocated guidance data. [in] error Task error
Implements GuidanceModelAbstractTpl< _Scalar >.
◆ createData()
| overridevirtual |
Allocate the cached guidance data.
- Returns
- Data object storing


Reimplemented from GuidanceModelAbstractTpl< _Scalar >.
◆ get_gain()
| const Scalar & get_gain | ( | ) | const |
Return the local linear gain.
- Returns
- The gain
◆ get_max_rate()
| const Scalar & get_max_rate | ( | ) | const |
Return the maximum desired-rate norm.
- Returns
- The saturation bound
◆ get_epsilon()
| const Scalar & get_epsilon | ( | ) | const |
Return the smoothing parameter.
- Returns
- The smoothing value

◆ set_gain()
| void set_gain | ( | const Scalar & | gain | ) |
Update the local linear gain.
- Parameters
[in] gain New local linear gain 

◆ set_max_rate()
| void set_max_rate | ( | const Scalar & | max_rate | ) |
Update the maximum desired-rate norm.
- Parameters
[in] max_rate New saturation bound 

◆ set_epsilon()
| void set_epsilon | ( | const Scalar & | epsilon | ) |
Update the smoothing parameter.
- Parameters
[in] epsilon New smoothing value
◆ print()
| overridevirtual |
Print the model parameters.
- Parameters
[out] os Output stream.
Reimplemented from GuidanceModelAbstractTpl< _Scalar >.
Member Data Documentation
◆ Scalar
| EIGEN_MAKE_ALIGNED_OPERATOR_NEW typedef _Scalar Scalar |
Definition at line 40 of file smooth-saturation.hpp.
The documentation for this class was generated from the following files:
- /build/source/include/crocoddyl/core/fwd.hpp
- /build/source/include/crocoddyl/core/guidance/smooth-saturation.hpp
