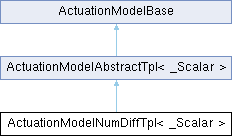
This class computes the numerical differentiation of an actuation model. More...
#include <actuation.hpp>
Public Types | |
| typedef ActuationDataAbstractTpl< Scalar > | ActuationDataAbstract |
| typedef ActuationModelAbstractTpl< Scalar > | Base |
| typedef ActuationDataNumDiffTpl< Scalar > | Data |
| typedef MathBaseTpl< Scalar > | MathBase |
| typedef MathBase::MatrixXs | MatrixXs |
| typedef MathBase::VectorXs | VectorXs |
| Public Types inherited from ActuationModelAbstractTpl< _Scalar > | |
| typedef ActuationDataAbstractTpl< Scalar > | ActuationDataAbstract |
| typedef MathBaseTpl< Scalar > | MathBase |
| typedef MathBase::MatrixXs | MatrixXs |
| typedef StateAbstractTpl< Scalar > | StateAbstract |
| typedef MathBase::VectorXs | VectorXs |
Public Member Functions | |
| ActuationModelNumDiffTpl (std::shared_ptr< Base > model) | |
| Initialize the numdiff residual model. | |
| virtual | ~ActuationModelNumDiffTpl ()=default |
| Destroy the numdiff actuation model. | |
| virtual void | calc (const std::shared_ptr< ActuationDataAbstract > &data, const Eigen::Ref< const VectorXs > &x) |
| Ignore the computation of the actuation signal. | |
| virtual void | calc (const std::shared_ptr< ActuationDataAbstract > &data, const Eigen::Ref< const VectorXs > &x, const Eigen::Ref< const VectorXs > &u) override |
Compute the actuation signal from the state point   | |
| virtual void | calcDiff (const std::shared_ptr< ActuationDataAbstract > &data, const Eigen::Ref< const VectorXs > &x) |
| virtual void | calcDiff (const std::shared_ptr< ActuationDataAbstract > &data, const Eigen::Ref< const VectorXs > &x, const Eigen::Ref< const VectorXs > &u) override |
| Compute the Jacobians of the actuation function. | |
| template<typename NewScalar> | |
| ActuationModelNumDiffTpl< NewScalar > | cast () const |
| virtual void | commands (const std::shared_ptr< ActuationDataAbstract > &data, const Eigen::Ref< const VectorXs > &x, const Eigen::Ref< const VectorXs > &tau) override |
| Compute the joint torque input from the generalized torques. | |
| virtual std::shared_ptr< ActuationDataAbstract > | createData () override |
| Create the actuation data. | |
| const Scalar | get_disturbance () const |
| Return the disturbance constant used by the numerical differentiation routine. | |
| const std::shared_ptr< Base > & | get_model () const |
| Return the original actuation model. | |
| void | set_disturbance (const Scalar disturbance) |
| Modify the disturbance constant used by the numerical differentiation routine. | |
| virtual void | torqueTransform (const std::shared_ptr< ActuationDataAbstract > &data, const Eigen::Ref< const VectorXs > &x, const Eigen::Ref< const VectorXs > &u) override |
| Compute the torque transform from generalized torques to joint torque inputs. | |
| Public Member Functions inherited from ActuationModelAbstractTpl< _Scalar > | |
| ActuationModelAbstractTpl (std::shared_ptr< StateAbstract > state, const std::size_t nu) | |
| Initialize the actuation model. | |
| void | calc (const std::shared_ptr< ActuationDataAbstract > &data, const Eigen::Ref< const VectorXs > &x) |
| Ignore the computation of the actuation signal. | |
| void | calcDiff (const std::shared_ptr< ActuationDataAbstract > &data, const Eigen::Ref< const VectorXs > &x) |
| Ignore the computation of the Jacobians of the actuation function. | |
| std::size_t | get_nu () const |
| Return the dimension of the joint-torque input. | |
| const std::shared_ptr< StateAbstract > & | get_state () const |
| Return the state. | |
| const VectorXs & | get_u_lb () const |
| Return the actuation lower bound. | |
| const VectorXs & | get_u_ub () const |
| Return the actuation upper bound. | |
| virtual void | print (std::ostream &os) const |
| Print relevant information of the residual model. | |
| void | set_u_lb (const VectorXs &u_lb) |
| Modify the actuation lower bounds. | |
| void | set_u_ub (const VectorXs &u_ub) |
| Modify the actuation upper bounds. | |
Public Attributes | |
| EIGEN_MAKE_ALIGNED_OPERATOR_NEW typedef _Scalar | Scalar |
| Public Attributes inherited from ActuationModelAbstractTpl< _Scalar > | |
| EIGEN_MAKE_ALIGNED_OPERATOR_NEW typedef _Scalar | Scalar |
Protected Attributes | |
| std::size_t | nu_ |
| Dimension of joint torque inputs. | |
| Protected Attributes inherited from ActuationModelAbstractTpl< _Scalar > | |
| std::size_t | nu_ |
| Dimension of joint torque inputs. | |
| std::shared_ptr< StateAbstract > | state_ |
| Model of the state. | |
| VectorXs | u_lb_ |
| Lower actuation limits. | |
| VectorXs | u_ub_ |
| Upper actuation limits. | |
Detailed Description
class crocoddyl::ActuationModelNumDiffTpl< _Scalar >
This class computes the numerical differentiation of an actuation model.
It computes the Jacobian of the residual model via numerical differentiation, i.e., 


- See also
- ActuationModelAbstractTpl(), calcDiff()
Definition at line 31 of file actuation.hpp.
Member Typedef Documentation
◆ MathBase
| typedef MathBaseTpl<Scalar> MathBase |
Definition at line 37 of file actuation.hpp.
◆ Base
| typedef ActuationModelAbstractTpl<Scalar> Base |
Definition at line 38 of file actuation.hpp.
◆ Data
| typedef ActuationDataNumDiffTpl<Scalar> Data |
Definition at line 39 of file actuation.hpp.
◆ ActuationDataAbstract
| typedef ActuationDataAbstractTpl<Scalar> ActuationDataAbstract |
Definition at line 40 of file actuation.hpp.
◆ VectorXs
| typedef MathBase::VectorXs VectorXs |
Definition at line 41 of file actuation.hpp.
◆ MatrixXs
| typedef MathBase::MatrixXs MatrixXs |
Definition at line 42 of file actuation.hpp.
Constructor & Destructor Documentation
◆ ActuationModelNumDiffTpl()
| explicit |
Initialize the numdiff residual model.
- Parameters
model Actuation model that we want to apply the numerical differentiation
Member Function Documentation
◆ calc() [1/2]
| overridevirtual |
Compute the actuation signal from the state point
- Parameters
[in] data Actuation data [in] x State point 
[in] u Joint-torque input 
Implements ActuationModelAbstractTpl< _Scalar >.
◆ calc() [2/2]
| virtual |
Ignore the computation of the actuation signal.
It does not update the actuation signal as this function is used in the terminal nodes of an optimal control problem.
- Parameters
[in] data Actuation data [in] x State point
◆ calcDiff() [1/2]
| overridevirtual |
Compute the Jacobians of the actuation function.
- Parameters
[in] data Actuation data [in] x State point [in] u Joint-torque input
Implements ActuationModelAbstractTpl< _Scalar >.
◆ calcDiff() [2/2]
| virtual |
◆ commands()
| overridevirtual |
Compute the joint torque input from the generalized torques.
It stores the results in ActuationDataAbstractTpl::u.
- Parameters
[in] data Actuation data [in] x State point [in] tau Generalized torques 

Implements ActuationModelAbstractTpl< _Scalar >.
◆ torqueTransform()
| overridevirtual |
Compute the torque transform from generalized torques to joint torque inputs.
It stores the results in ActuationDataAbstractTpl::Mtau.
- Parameters
[in] data Actuation data [in] x State point [in] tau Joint-torque inputs
Reimplemented from ActuationModelAbstractTpl< _Scalar >.
◆ createData()
| overridevirtual |
Create the actuation data.
- Returns
- the actuation data
Reimplemented from ActuationModelAbstractTpl< _Scalar >.
Member Data Documentation
◆ Scalar
| EIGEN_MAKE_ALIGNED_OPERATOR_NEW typedef _Scalar Scalar |
Definition at line 36 of file actuation.hpp.
◆ nu_
| protected |
Dimension of joint torque inputs.
Definition at line 193 of file actuation-base.hpp.
The documentation for this class was generated from the following files:
- /build/source/include/crocoddyl/core/fwd.hpp
- /build/source/include/crocoddyl/core/numdiff/actuation.hpp
